
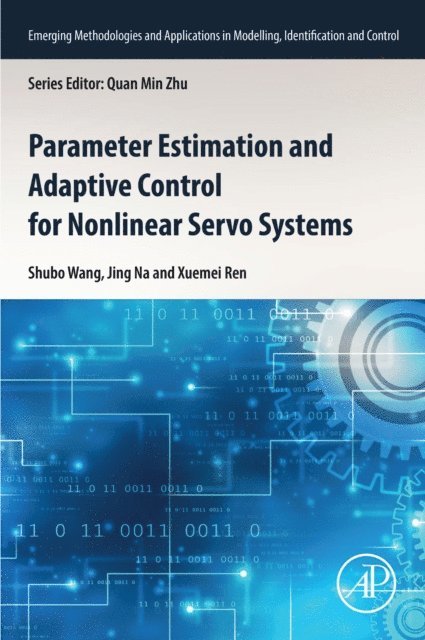
Parameter Estimation and Adaptive Control for Nonlinear Servo Systems
Xuemei Ren, Jing Na, Shubo Wang
E-bok
20242 260 kr
1 589 kr
Beställningsvara. Skickas inom 10-15 vardagar. Fri frakt över 249 kr.
Parameter Estimation and Adaptive Control for Nonlinear Servo Systems presents the latest advances in observer-based control design, focusing on adaptive control for nonlinear systems such as adaptive neural network control, adaptive parameter estimation, and system identification. This book offers an array of new, real-world applications in the field. Written by eminent scientists in the field of control theory, this book covers the latest advances in observer-based control design and provides fundamentals, algorithms, and key applications in the fields of power systems, robotics and mechatronics, flight, and automotive systems.
Xuemei Ren, Jing Na, Shubo Wang
2 260 kr
Qiang Chen, Shuzong Xie, Xiongxiong He, Shubo Wang
Häftad, 2026
2 518 kr
Shubo Wang, Xiongxiong He, Shuzong Xie, Qiang Chen
3 189 kr
Jing Na, Qiang Chen, Xuemei Ren
Häftad, 2018
1 540 kr

Jiwei Wen, Alireza Nasiri, Sing Kiong Nguang, Dhafer J. Almakhles
Häftad, 2019
1 178 kr
Yang Li, Jianhua Zhang, Wu Qiong
Häftad, 2018
1 565 kr
Olfa Boubaker, Sajad Jafari
Häftad, 2018
1 489 kr
Olfa Boubaker, Quanmin Zhu, Magdi S. Mahmoud, Jose Ragot, Hamid Reza Karimi, Jorge D�vila
Häftad, 2019
1 451 kr
Olfa Boubaker, Quanmin Zhu, Magdi S. Mahmoud, Jose Ragot, Hamid Reza Karimi, Jorge D�vila
Häftad, 2019
1 489 kr
Lijing Dong, Sing Kiong Nguang
Häftad, 2020
1 477 kr

Chunhua Yang, Bei Sun
Häftad, 2021
1 938 kr
Xuemei Ren, Jing Na, Shubo Wang
2 260 kr
Jing Na, Qiang Chen, Xuemei Ren
Häftad, 2018
1 540 kr
Xuemei Ren, Qiang Chen, Jing Na
2 206 kr
Qiang Chen, Shuzong Xie, Xiongxiong He, Shubo Wang
Häftad, 2026
2 518 kr
Shubo Wang, Xiongxiong He, Shuzong Xie, Qiang Chen
3 189 kr
Xing Wu, Jing Na, Quanmin Zhu
1 427 kr
Quanmin Zhu, Jing Na, Xing Wu
Inbunden, 2018
1 102 kr
Quanmin Zhu, Jing Na, Xing Wu
Häftad, 2019
1 102 kr

Ahmed G. Radwan, Farooq Ahmad Khanday, Lobna A. Said
Häftad, 2021
1 978 kr
1 589 kr
Beställningsvara. Skickas inom 10-15 vardagar. Fri frakt över 249 kr.
Parameter Estimation and Adaptive Control for Nonlinear Servo Systems presents the latest advances in observer-based control design, focusing on adaptive control for nonlinear systems such as adaptive neural network control, adaptive parameter estimation, and system identification. This book offers an array of new, real-world applications in the field. Written by eminent scientists in the field of control theory, this book covers the latest advances in observer-based control design and provides fundamentals, algorithms, and key applications in the fields of power systems, robotics and mechatronics, flight, and automotive systems.
Xuemei Ren, Jing Na, Shubo Wang
2 260 kr
Qiang Chen, Shuzong Xie, Xiongxiong He, Shubo Wang
Häftad, 2026
2 518 kr
Shubo Wang, Xiongxiong He, Shuzong Xie, Qiang Chen
3 189 kr
Jing Na, Qiang Chen, Xuemei Ren
Häftad, 2018
1 540 kr
Jiwei Wen, Alireza Nasiri, Sing Kiong Nguang, Dhafer J. Almakhles
Häftad, 2019
1 178 kr
Yang Li, Jianhua Zhang, Wu Qiong
Häftad, 2018
1 565 kr
Olfa Boubaker, Sajad Jafari
Häftad, 2018
1 489 kr
Olfa Boubaker, Quanmin Zhu, Magdi S. Mahmoud, Jose Ragot, Hamid Reza Karimi, Jorge D�vila
Häftad, 2019
1 451 kr
Olfa Boubaker, Quanmin Zhu, Magdi S. Mahmoud, Jose Ragot, Hamid Reza Karimi, Jorge D�vila
Häftad, 2019
1 489 kr
Lijing Dong, Sing Kiong Nguang
Häftad, 2020
1 477 kr
Chunhua Yang, Bei Sun
Häftad, 2021
1 938 kr
Xuemei Ren, Jing Na, Shubo Wang
2 260 kr
Jing Na, Qiang Chen, Xuemei Ren
Häftad, 2018
1 540 kr
Xuemei Ren, Qiang Chen, Jing Na
2 206 kr
Qiang Chen, Shuzong Xie, Xiongxiong He, Shubo Wang
Häftad, 2026
2 518 kr
Shubo Wang, Xiongxiong He, Shuzong Xie, Qiang Chen
3 189 kr
Xing Wu, Jing Na, Quanmin Zhu
1 427 kr
Quanmin Zhu, Jing Na, Xing Wu
Inbunden, 2018
1 102 kr
Quanmin Zhu, Jing Na, Xing Wu
Häftad, 2019
1 102 kr
Ahmed G. Radwan, Farooq Ahmad Khanday, Lobna A. Said
Häftad, 2021
1 978 kr
1 589 kr
Beställningsvara. Skickas inom 10-15 vardagar. Fri frakt över 249 kr.
Parameter Estimation and Adaptive Control for Nonlinear Servo Systems presents the latest advances in observer-based control design, focusing on adaptive control for nonlinear systems such as adaptive neural network control, adaptive parameter estimation, and system identification. This book offers an array of new, real-world applications in the field. Written by eminent scientists in the field of control theory, this book covers the latest advances in observer-based control design and provides fundamentals, algorithms, and key applications in the fields of power systems, robotics and mechatronics, flight, and automotive systems.
Xuemei Ren, Jing Na, Shubo Wang
2 260 kr
Qiang Chen, Shuzong Xie, Xiongxiong He, Shubo Wang
Häftad, 2026
2 518 kr
Shubo Wang, Xiongxiong He, Shuzong Xie, Qiang Chen
3 189 kr
Jing Na, Qiang Chen, Xuemei Ren
Häftad, 2018
1 540 kr
Jiwei Wen, Alireza Nasiri, Sing Kiong Nguang, Dhafer J. Almakhles
Häftad, 2019
1 178 kr
Yang Li, Jianhua Zhang, Wu Qiong
Häftad, 2018
1 565 kr
Olfa Boubaker, Sajad Jafari
Häftad, 2018
1 489 kr
Olfa Boubaker, Quanmin Zhu, Magdi S. Mahmoud, Jose Ragot, Hamid Reza Karimi, Jorge D�vila
Häftad, 2019
1 451 kr
Olfa Boubaker, Quanmin Zhu, Magdi S. Mahmoud, Jose Ragot, Hamid Reza Karimi, Jorge D�vila
Häftad, 2019
1 489 kr
Lijing Dong, Sing Kiong Nguang
Häftad, 2020
1 477 kr
Chunhua Yang, Bei Sun
Häftad, 2021
1 938 kr
Xuemei Ren, Jing Na, Shubo Wang
2 260 kr
Jing Na, Qiang Chen, Xuemei Ren
Häftad, 2018
1 540 kr
Xuemei Ren, Qiang Chen, Jing Na
2 206 kr
Qiang Chen, Shuzong Xie, Xiongxiong He, Shubo Wang
Häftad, 2026
2 518 kr
Shubo Wang, Xiongxiong He, Shuzong Xie, Qiang Chen
3 189 kr
Xing Wu, Jing Na, Quanmin Zhu
1 427 kr
Quanmin Zhu, Jing Na, Xing Wu
Inbunden, 2018
1 102 kr
Quanmin Zhu, Jing Na, Xing Wu
Häftad, 2019
1 102 kr
Ahmed G. Radwan, Farooq Ahmad Khanday, Lobna A. Said
Häftad, 2021
1 978 kr