
Del 33
Del 261 i serien Lecture Notes in Control and Information Sciences
556 kr
Beställningsvara. Skickas inom 10-15 vardagar. Fri frakt över 249 kr.
Ehsan Sobhani-Tehrani, Khashayar Khorasani
Häftad, 2009
1 653 kr
Heidar A. Talebi, Farzaneh Abdollahi, Rajni V. Patel, Khashayar Khorasani
Häftad, 2009
1 106 kr
Daniel Alberer, Håkan Hjalmarsson, Luigi del Re
Häftad, 2011
1 104 kr
Qingling Zhang, Chao Liu, Xue Zhang
Häftad, 2012
1 104 kr
Maria Letizia Corradini, Andrea Cristofaro, Fabio Giannoni, Giuseppe Orlando
Häftad, 2012
556 kr
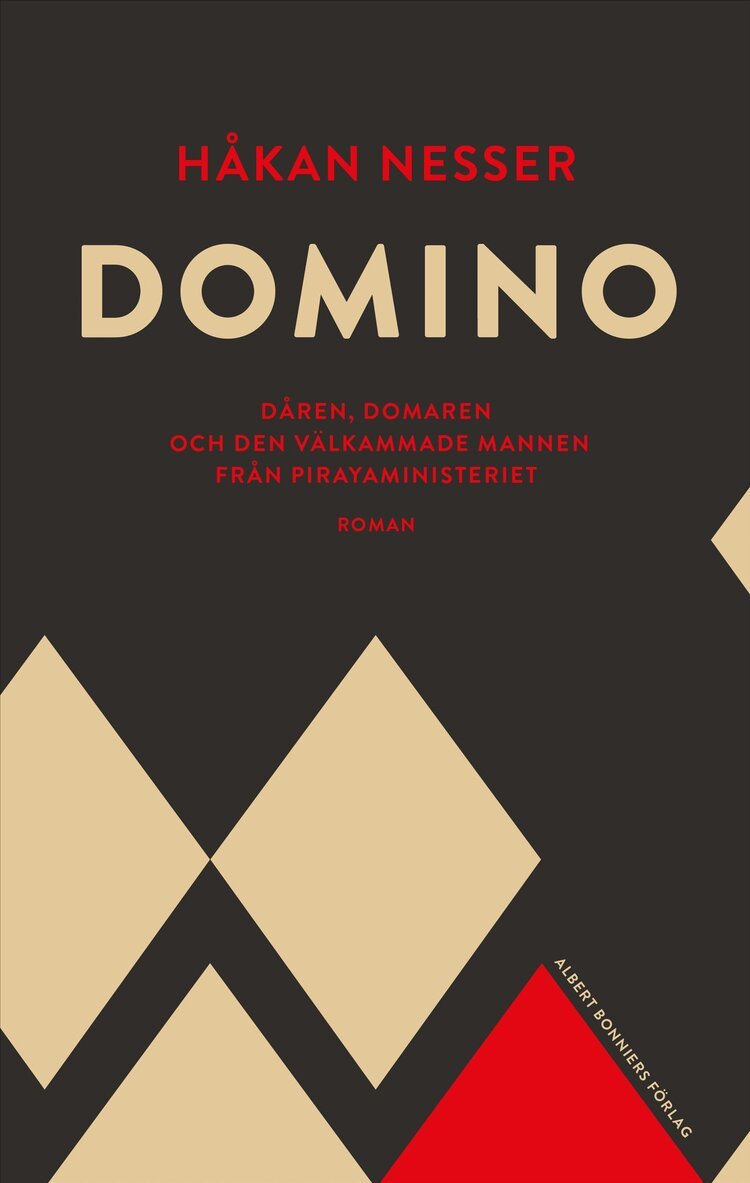
Håkan Nesser
Inbunden, 2026
220 kr259 kr
Del 261 i serien Lecture Notes in Control and Information Sciences
556 kr
Beställningsvara. Skickas inom 10-15 vardagar. Fri frakt över 249 kr.
Ehsan Sobhani-Tehrani, Khashayar Khorasani
Häftad, 2009
1 653 kr
Heidar A. Talebi, Farzaneh Abdollahi, Rajni V. Patel, Khashayar Khorasani
Häftad, 2009
1 106 kr
Daniel Alberer, Håkan Hjalmarsson, Luigi del Re
Häftad, 2011
1 104 kr
Qingling Zhang, Chao Liu, Xue Zhang
Häftad, 2012
1 104 kr
Maria Letizia Corradini, Andrea Cristofaro, Fabio Giannoni, Giuseppe Orlando
Häftad, 2012
556 kr
Håkan Nesser
Inbunden, 2026
220 kr259 kr