Ángel P. del Pobil – författare
Visar alla böcker från författaren Ángel P. del Pobil. Handla med fri frakt och snabb leverans.
16 produkter
Robust Motion Detection in Real-Life Scenarios
Av Ester Martínez-Martín, Ángel P. del Pobil
Häftad, 2012
568 kr
Lägg i varukorg
This work proposes a complete sensor-independent visual system that provides robust target motion detection. First, the way sensors obtain images, in terms of resolution distribution and pixel neighbourhood, is studied. This allows a spatial analysis of motion to be carried out. Then, a novel …
Robust Motion Detection in Real-Life Scenarios
Av Angel P. del Pobil, Ester Martinez-Martin
E-bok, 2012
755 kr
Lägg i varukorg
This work proposes a complete sensor-independent visual system that provides robust target motion detection. First, the way sensors obtain images, in terms of resolution distribution and pixel neighbourhood, is studied. This allows a spatial analysis of motion to be carried out. Then, a novel …
Metrics of Sensory Motor Coordination and Integration in Robots and Animals
How to Measure the Success of Bioinspired Solutions with Respect to their Natural Models, and Against More ‘Artificial’ Solutions?
Av Fabio Bonsignorio, Elena Messina m. fl.
Inbunden, 2019
1098 kr
Lägg i varukorg
This book focuses on a critical issue in the study of physical agents, whether natural or artificial: the quantitative modelling of sensory–motor coordination.Adopting a novel approach, it defines a common scientific framework for both the intelligent systems designed by engineers and those that …
Metrics of Sensory Motor Coordination and Integration in Robots and Animals
How to Measure the Success of Bioinspired Solutions with Respect to their Natural Models, and Against More ‘Artificial’ Solutions?
Av John Hallam, Angel P. del Pobil m. fl.
E-bok, 2019
1459 kr
Lägg i varukorg
This book focuses on a critical issue in the study of physical agents, whether natural or artificial: the quantitative modelling of sensory–motor coordination. Adopting a novel approach, it defines a common scientific framework for both the intelligent systems designed by engineers and those that …
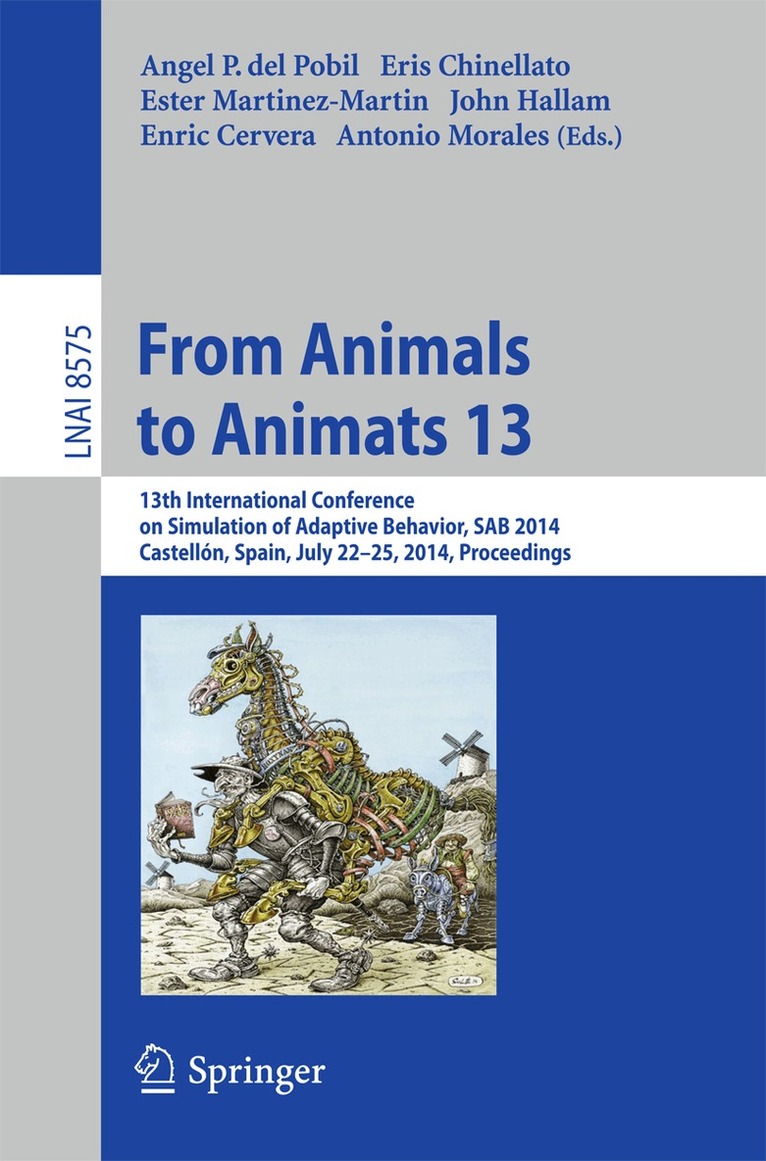
From Animals to Animats 13
13th International Conference on Simulation of Adaptive Behavior, SAB 2014, Castellón, Spain, July 22-25, 2014, Proceedings
Av Angel P. del Pobil, Eris Chinellato m. fl.
Häftad, 2014
551 kr
Lägg i varukorg
This book constitutes the proceedings of the 13th International Conference on Simulation of Adaptive Behavior, SAB 2014, held in Castellón, Spain, in July 2014. The 32 papers presented in this volume were carefully reviewed and selected for inclusion in the proceedings. They cover the main areas in …
From Animals to Animats 13
13th International Conference on Simulation of Adaptive Behavior, SAB 2014, Castellón, Spain, July 22-25, 2014, Proceedings
Av Antonio Morales, Enric Cervera m. fl.
E-bok, 2014
732 kr
Lägg i varukorg
This book constitutes the proceedings of the 13th International Conference on Simulation of Adaptive Behavior, SAB 2014, held in Castellón, Spain, in July 2014. The 32 papers presented in this volume were carefully reviewed and selected for inclusion in the proceedings. They cover the main areas in …
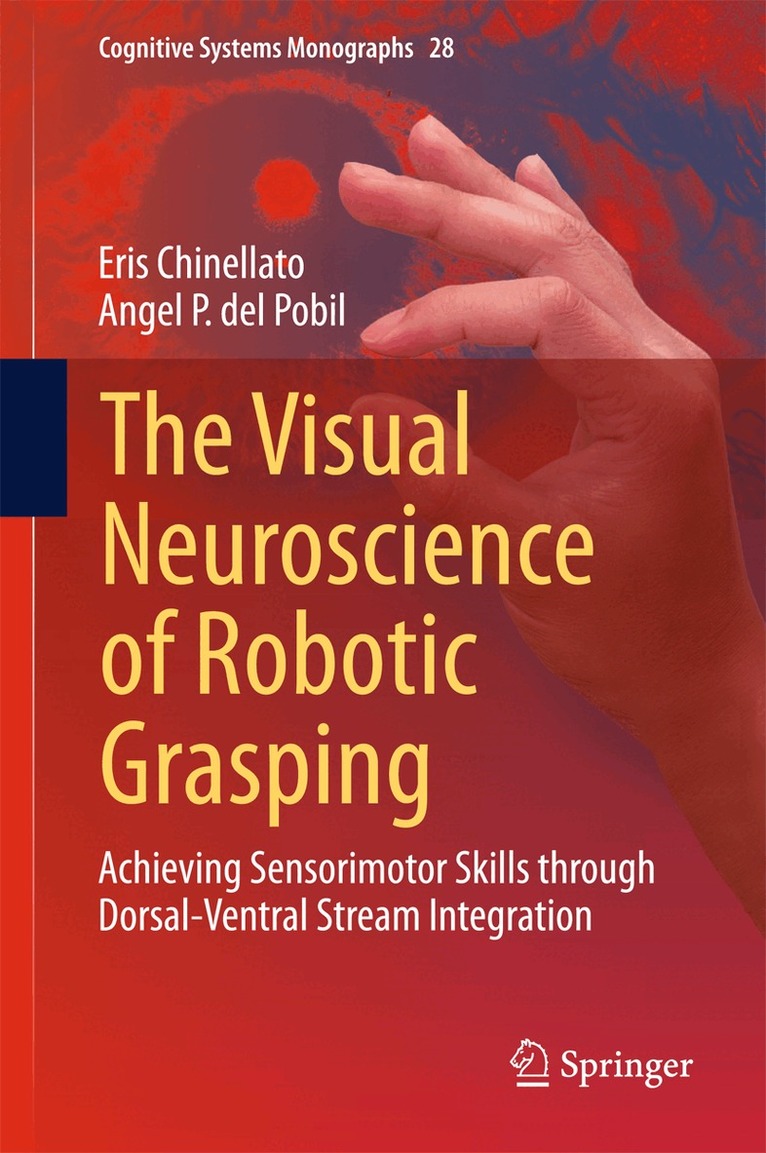
Visual Neuroscience of Robotic Grasping
Achieving Sensorimotor Skills through Dorsal-Ventral Stream Integration
Av Eris Chinellato, Angel P. del Pobil
Inbunden, 2015
1098 kr
Lägg i varukorg
This book presents interdisciplinary research that pursues the mutual enrichment of neuroscience and robotics. Building on experimental work, and on the wealth of literature regarding the two cortical pathways of visual processing - the dorsal and ventral streams - we define and implement, …
Visual Neuroscience of Robotic Grasping
Achieving Sensorimotor Skills through Dorsal-Ventral Stream Integration
Av Angel P. del Pobil, Eris Chinellato
E-bok, 2015
1459 kr
Lägg i varukorg
This book presents interdisciplinary research that pursues the mutual enrichment of neuroscience and robotics. Building on experimental work, and on the wealth of literature regarding the two cortical pathways of visual processing - the dorsal and ventral streams - we define and implement, …
Visual Neuroscience of Robotic Grasping
Achieving Sensorimotor Skills through Dorsal-Ventral Stream Integration
Av Eris Chinellato, Angel P. del Pobil
Häftad, 2016
1098 kr
Lägg i varukorg
This book presents interdisciplinary research that pursues the mutual enrichment of neuroscience and robotics. Building on experimental work, and on the wealth of literature regarding the two cortical pathways of visual processing - the dorsal and ventral streams - we define and implement, …
Spatial Representation and Motion Planning
Av Angel P. del Pobil, Miquel A. Serna
Häftad, 1995
551 kr
Lägg i varukorg
This book is devoted to the development of adequate spatial representations for robot motion planning. Drawing upon advanced heuristic techniques from AI and computational geometry, the authors introduce a general model for spatial representation of physical objects. This model is then applied to …
Tasks and Methods in Applied Artificial Intelligence
11th International Conference on Industrial and Engineering Applications of Artificial Intelligence and Expert Systems, IEA-98-AIE, Benicassim, Castellon, Spain, June, 1998 Proceedings, Volume II
Av Angel P. del Pobil, Jose Mira m. fl.
Häftad, 1998
1098 kr
Lägg i varukorg
This two-volume set constitutes the refereed proceedings of the 11th International Conference on Industrial and Engineering Applications of Artificial Intelligence and Expert Systems, IEA/AIE-98, held in Benicassim, Castellon, Spain, in June 1998.The two volumes present a total of 187 revised full …
Methodology and Tools in Knowledge-Based Systems
11th International Conference on Industrial and Engineering Applications of Artificial Intelligence and Expert Systems, IEA-98-AIE, Benicassim, Castellon, Spain, June, 1998 Proceedings, Volume I
Av Ali Moonis, Jose Mira m. fl.
E-bok, 2006
1427 kr
Lägg i varukorg
This two-volume set constitutes the refereed proceedings of the 11th International Conference on Industrial and Engineering Applications of Artificial Intelligence and Expert Systems, IEA/AIE-98, held in Benicassim, Castellon, Spain, in June 1998.The two volumes present a total of 187 revised full …
Robot Physical Interaction through the combination of Vision, Tactile and Force Feedback
Applications to Assistive Robotics
Av Mario Prats, Ángel P. del Pobil m. fl.
Inbunden, 2012
1098 kr
Lägg i varukorg
Robot manipulation is a great challenge; it encompasses versatility -adaptation to different situations-, autonomy -independent robot operation-, and dependability -for success under modeling or sensing errors. A complete manipulation task involves, first, a suitable grasp or contact configuration, …
Robot Physical Interaction through the combination of Vision, Tactile and Force Feedback
Applications to Assistive Robotics
Av Pedro J. Sanz, Angel P. del Pobil m. fl.
E-bok, 2012
1459 kr
Lägg i varukorg
Robot manipulation is a great challenge; it encompasses versatility -adaptation to different situations-, autonomy -independent robot operation-, and dependability -for success under modeling or sensing errors. A complete manipulation task involves, first, a suitable grasp or contact configuration, …
Robot Physical Interaction through the combination of Vision, Tactile and Force Feedback
Applications to Assistive Robotics
Av Mario Prats, Ángel P. del Pobil m. fl.
Häftad, 2014
1098 kr
Lägg i varukorg
Robot manipulation is a great challenge; it encompasses versatility -adaptation to different situations-, autonomy -independent robot operation-, and dependability -for success under modeling or sensing errors. A complete manipulation task involves, first, a suitable grasp or contact configuration, …