3 017 kr
Skickas inom 10-15 vardagar
3 017 kr
Skickas inom 10-15 vardagar
1 237 kr
Läs direkt efter köp
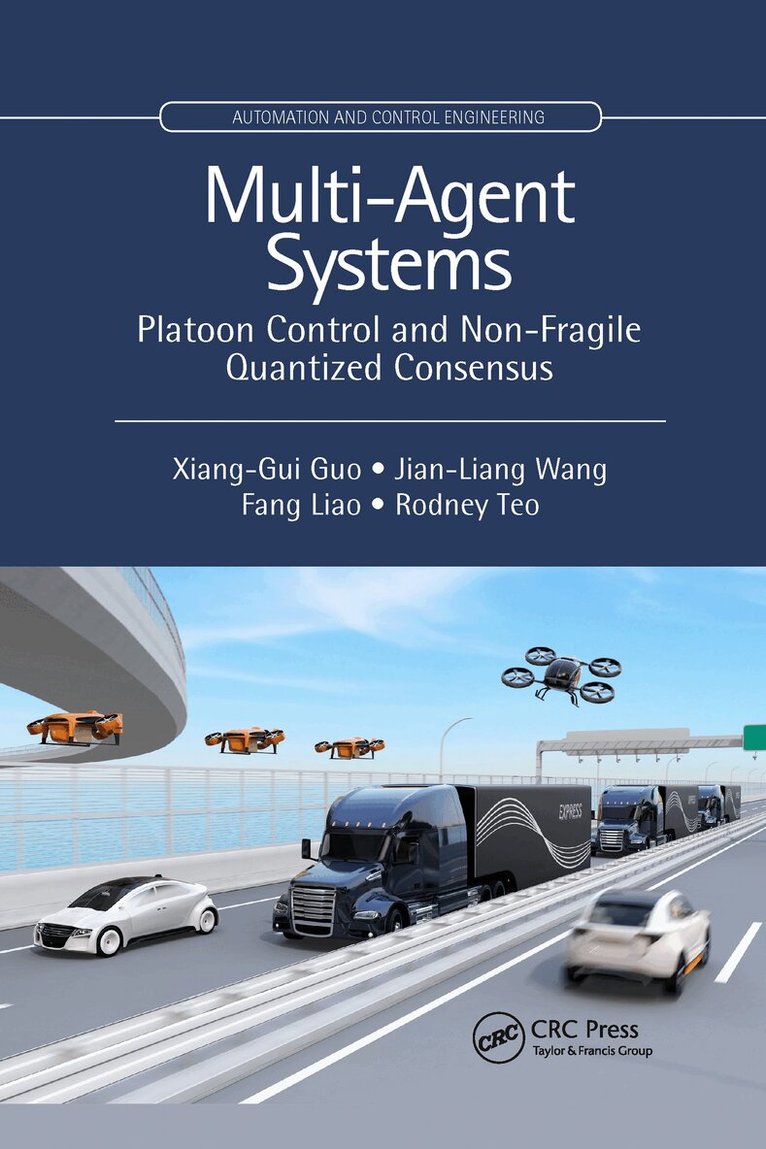
Multi-Agent Systems: Platoon Control and Non-Fragile Quantized Consensus aims to present recent research results in designing platoon control and non-fragile quantized consensus for multi-agent systems. The main feature of this book is that distributed adaptive sliding mode control (SMC) algorithms are proposed to guarantee strong string stability based on modified constant time headway (MCTH) policy. The MCTH policy is used to remove the unrealistic assumption in the most existing literature that initial spacing, velocity and acceleration errors are zero. This monograph investigates the platoon control issue by combining SMC technique with neural network and fuzzy logic system approximation methods.
1 237 kr
Läs direkt efter köp
Multi-Agent Systems: Platoon Control and Non-Fragile Quantized Consensus aims to present recent research results in designing platoon control and non-fragile quantized consensus for multi-agent systems. The main feature of this book is that distributed adaptive sliding mode control (SMC) algorithms are proposed to guarantee strong string stability based on modified constant time headway (MCTH) policy. The MCTH policy is used to remove the unrealistic assumption in the most existing literature that initial spacing, velocity and acceleration errors are zero. This monograph investigates the platoon control issue by combining SMC technique with neural network and fuzzy logic system approximation methods.
1 082 kr
Skickas inom 10-15 vardagar
1 653 kr
Skickas inom 10-15 vardagar
2 065 kr
Läs direkt efter köp
3 017 kr
Skickas inom 10-15 vardagar
1 237 kr
Läs direkt efter köp
Multi-Agent Systems: Platoon Control and Non-Fragile Quantized Consensus aims to present recent research results in designing platoon control and non-fragile quantized consensus for multi-agent systems. The main feature of this book is that distributed adaptive sliding mode control (SMC) algorithms are proposed to guarantee strong string stability based on modified constant time headway (MCTH) policy. The MCTH policy is used to remove the unrealistic assumption in the most existing literature that initial spacing, velocity and acceleration errors are zero. This monograph investigates the platoon control issue by combining SMC technique with neural network and fuzzy logic system approximation methods.
1 237 kr
Läs direkt efter köp
Multi-Agent Systems: Platoon Control and Non-Fragile Quantized Consensus aims to present recent research results in designing platoon control and non-fragile quantized consensus for multi-agent systems. The main feature of this book is that distributed adaptive sliding mode control (SMC) algorithms are proposed to guarantee strong string stability based on modified constant time headway (MCTH) policy. The MCTH policy is used to remove the unrealistic assumption in the most existing literature that initial spacing, velocity and acceleration errors are zero. This monograph investigates the platoon control issue by combining SMC technique with neural network and fuzzy logic system approximation methods.
1 082 kr
Skickas inom 10-15 vardagar
1 653 kr
Skickas inom 10-15 vardagar
2 065 kr
Läs direkt efter köp