• Fri frakt över 249 kr
  • •
  • Snabba leveranser
  • •
  • Billiga böcker
Kundservice

Du är på sajten för privatpersoner.

Företag, bibliotek eller offentlig verksamhet?

Du handlar på classic.bokus.com, där alla dina funktioner finns intakta.
Till classic.bokus.com
Bokus logotyp. Gå till startsidan.
  • Erbjudanden
  • Nyheter
  • Student
  • Topplistor
  • Barn & ungdom
  • Bokus Play
  • E-böcker
  • Pocketböcker
  • Spel & pussel

Upp till 20% på populära nyheter →

Sidfot

Mina sidor

    Hjälp

    • Kundservice
    • Vanliga frågor och svar
    • Frakt och leverans
    • Retur vid ångerrätt
    • Reklamera vara
    • Betalning
    • Köpvillkor
    • Allmänna villkor
    • Information om webbplatsens tillgänglighet

    Om Bokus

    • Om oss
    • Pressrum
    • För studenter
    • För företag
    • För bibliotek och offentlig verksamhet
    • För leverantörer
    • Hållbarhet

    Populärt

    • Aktuella erbjudanden
    • Presentkort
    • Studentlitteratur
    • Nya böcker
    • Topplistor
    • Signerade böcker
    • Engelska böcker

    Inspiration

    • Boktips
    • BookTok
    • Populära bokserier
    • Barnbokskaraktärer
    • Populära författare

    Mina sidor

      Hjälp

      • Kundservice
      • Vanliga frågor och svar
      • Frakt och leverans
      • Retur vid ångerrätt
      • Reklamera vara
      • Betalning
      • Köpvillkor
      • Allmänna villkor
      • Information om webbplatsens tillgänglighet

      Om Bokus

      • Om oss
      • Pressrum
      • För studenter
      • För företag
      • För bibliotek och offentlig verksamhet
      • För leverantörer
      • Hållbarhet

      Populärt

      • Aktuella erbjudanden
      • Presentkort
      • Studentlitteratur
      • Nya böcker
      • Topplistor
      • Signerade böcker
      • Engelska böcker

      Inspiration

      • Boktips
      • BookTok
      • Populära bokserier
      • Barnbokskaraktärer
      • Populära författare
      Logotyp för Bokus
      Följ oss på Facebook (extern länk)Följ oss på Instagram (extern länk)Följ oss på YouTube (extern länk)Följ oss på TikTok (extern länk)
      bokus @ CookiesIntegritetspolicyKöpvillkor
      Till Citymail hemsida (extern länk)Till Budbee hemsida (extern länk)Till Postnord hemsida (extern länk)Till Schenker hemsida (extern länk)Till Early Bird hemsida (extern länk)Till Walleys hemsida (extern länk)
      1. Data och IT
      2. Systemvetenskap och AI

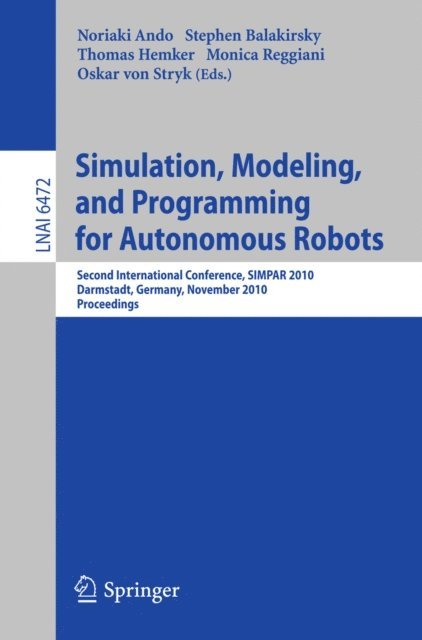
      Simulation, Modeling, and Programming for Autonomous Robots

      Second International Conference, SIMPAR 2010, Darmstadt, Germany, November 15-18, 2010, Proceedings

      AvNoriako Ando,Stephen Balakirsky

      Häftad, Engelska, 2010

      Del i serien Lecture Notes in Computer Science

      570 kr

      Beställningsvara. Skickas inom 5-8 vardagar. Fri frakt över 249 kr.

      Beskrivning

      Why are the many highly capable autonomous robots that have been promised for novel applications driven by society, industry, and research not available - day despite the tremendous progress in robotics science and systems achieved during the last decades? Unfortunately, steady improvements in speci?c robot abilities and robot hardware have not been matched by corresponding robot performance in real world environments. This is mainly due to the lack of - vancements in robot software that master the development of robotic systems of ever increasing complexity. In addition, fundamental open problems are still awaiting sound answers while the development of new robotics applications s- fersfromthelackofwidelyusedtools,libraries,andalgorithmsthataredesigned in a modular and performant manner with standardized interfaces. Simulation environments are playing a major role not only in reducing development time and cost, e. g. , by systematic software- or hardware-in-the-loop testing of robot performance, but also in exploring new types of robots and applications. H- ever,their use may still be regardedwith skepticism. Seamless migrationof code using robot simulators to real-world systems is still a rare circumstance, due to the complexity of robot, world, sensor, and actuator modeling. These challenges drive the quest for the next generation of methodologies and tools for robot development. The objective of the International Conference on Simulation, Modeling, and ProgrammingforAutonomous Robots (SIMPAR) is to o?er a unique forum for these topics and to bring together researchersfrom academia and industry to identify and solve the key issues necessary to ease the development of increasingly complex robot software.

      Produktinformation

      • Utgivningsdatum:2010-11-05
      • Format:Häftad
      • Språk:Engelska
      • Serie:Lecture Notes in Computer Science
      • Antal sidor:558
      • Förlag:Springer-Verlag Berlin and Heidelberg GmbH & Co. KG
      • ISBN:9783642173189

      Utforska kategorier

      • Systemvetenskap och AI inom Data och IT
      • Programvaruutveckling inom Data och IT
      • Artificiell intelligens inom Data och IT

      Innehållsförteckning

      • Invited Talks.- Building Blocks for Mobile Manipulation.- Natural Human-Robot Interaction.- Robots and the Human.- The Modelica Object-Oriented Equation-Based Language and Its OpenModelica Environment with MetaModeling, Interoperability, and Parallel Execution.- Simulation.- Blender for Robotics: Integration into the Leuven Paradigm for Robot Task Specification and Human Motion Estimation.- Simulating the C2SM ‘Fast’ Robot.- Extending Open Dynamics Engine for Robotics Simulation.- Virtual Robot Experimentation Platform V-REP: A Versatile 3D Robot Simulator.- Evaluation and Enhancement of Common Simulation Methods for Robotic Range Sensors.- High Fidelity Sensor Simulations for the Virtual Autonomous Navigation Environment.- GPS/Galileo Testbed Using a High Precision Optical Positioning System.- Validating Vision and Robotic Algorithms for Dynamic Real World Environments.- OpenGRASP: A Toolkit for Robot Grasping Simulation.- NERD Neurodynamics and Evolutionary Robotics Development Kit.- Simulation and Evaluation of Mixed-Mode Environments: Towards Higher Quality of Simulations.- Evaluating a Physics Engine as an Ingredient for Physical Reasoning.- Simulating Vehicle Kinematics with SimVis3D and Newton.- Programming.- Coordinating Software Components in a Component-Based Architecture for Robotics.- Native Robot Software Framework Inter-operation.- Run-Time Management of Component-Based Robot Software from a Command Line.- Modelling Behaviour Requirements for Automatic Interpretation, Simulation and Deployment.- Implementing Automated Robot Task Planning and Execution Based on Description Logic KB.- On the Way to High-Level Programming for Resource-Limited Embedded Systems with Golog.- RobustHX - The Robust Middleware Library for Hexor Robots.- RoboComp: A Tool-BasedRobotics Framework.- Improving a Robotics Framework with Real-Time and High-Performance Features.- Implementation of Distributed Production System for Heterogeneous Multiprocessor Robotic Systems.- Robot Programming by Demonstration.- Design Principles of the Component-Based Robot Software Framework Fawkes.- Handling Hardware Heterogeneity through Rich Interfaces in a Component Model for Autonomous Robotics.- Design Abstraction and Processes in Robotics: From Code-Driven to Model-Driven Engineering.- Applications.- Using Simulation to Assess the Effectiveness of Pallet Stacking Methods.- Analysing Mixed Reality Simulation for Industrial Applications: A Case Study in the Development of a Robotic Screw Remover System.- A Parameterless Biologically Inspired Control Algorithm Robust to Nonlinearities, Dead-Times and Low-Pass Filtering Effects.- Exploration Strategies for a Robot with a Continously Rotating 3D Scanner.- Validating an Active Stereo System Using USARSim.- Performance Analysis for Multi-robot Exploration Strategies.- Dynamic Modeling of the 4 DoF BioRob Series Elastic Robot Arm for Simulation and Control.- Static Balance for Rescue Robot Navigation: Discretizing Rotational Motion within Random Step Environment.- Discovery, Localization and Recognition of Smart Objects by a Mobile Robot.- Simulation for the Optimal Design of a Biped Robot: Analysis of Energy Consumption.- Efficient Use of 3D Environment Models for Mobile Robot Simulation and Localization.- Decision and Coordination Strategies for RoboCup Rescue Agents.- Swarm Dispersion via Potential Fields, Leader Election, and Counting Hops.- Compliant Robot Actuation by Feedforward Controlled Emulated Spring Stiffness.- Different Approaches in Feeding of a Flexible Manufacturing Cell.- On the Stability of Bipedal Walking.- An Approach to Close the Gap between Simulation and Real Robots.- Accelerating Point-Based POMDP Algorithms via Greedy Strategies.
      Hoppa över listan

      Du kanske också är intresserad av

      Oskar von Stryk, Monica Reggiani, Thomas Hemker, Stephen Balakirsky, Noriako Ando - Simulation, Modeling, and Programming for Autonomous Robots, E-bok

      Simulation, Modeling, and Programming for Autonomous Robots

      Oskar von Stryk, Monica Reggiani, Thomas Hemker, Stephen Balakirsky, Noriako Ando

      E-bok
      2010

      734 kr

      Stefano Carpin, Itsuki Noda, Enrico Pagello, Monica Reggiani - Simulation, Modeling, and Programming for Autonomous Robots, Häftad

      Simulation, Modeling, and Programming for Autonomous Robots

      Stefano Carpin, Itsuki Noda, Enrico Pagello, Monica Reggiani

      Häftad, 2008

      581 kr

      James J. Kuffner, Davide Brugali, Noriako Ando, Itsuki Noda - Simulation, Modeling, and Programming for Autonomous Robots, E-bok

      Simulation, Modeling, and Programming for Autonomous Robots

      James J. Kuffner, Davide Brugali, Noriako Ando, Itsuki Noda

      E-bok
      2012

      739 kr

      Dirk Holz, Katie Genter, Maarouf Saad, Oskar von Stryk - RoboCup 2018: Robot World Cup XXII, Häftad
      Del 11374

      RoboCup 2018: Robot World Cup XXII

      Dirk Holz, Katie Genter, Maarouf Saad, Oskar von Stryk

      Häftad, 2019

      949 kr

      Oskar von Stryk, Maarouf Saad, Katie Genter, Dirk Holz - RoboCup 2018: Robot World Cup XXII, E-bok

      RoboCup 2018: Robot World Cup XXII

      Oskar von Stryk, Maarouf Saad, Katie Genter, Dirk Holz

      E-bok
      2019

      1 150 kr

      Itsuki Noda, Noriako Ando, Davide Brugali, James J. Kuffner - Simulation, Modeling, and Programming for Autonomous Robots, Häftad

      Simulation, Modeling, and Programming for Autonomous Robots

      Itsuki Noda, Noriako Ando, Davide Brugali, James J. Kuffner

      Häftad, 2012

      581 kr

      Monica Reggiani, Enrico Pagello, Itsuki Noda, Stefano Carpin - Simulation, Modeling, and Programming for Autonomous Robots, E-bok

      Simulation, Modeling, and Programming for Autonomous Robots

      Monica Reggiani, Enrico Pagello, Itsuki Noda, Stefano Carpin

      E-bok
      2008

      732 kr

      Sebastian Tadros - SIGNERAD - Vad vill du bli när du blir stor?, Kartonnage
      • Signerad!

      SIGNERAD - Vad vill du bli när du blir stor?

      Sebastian Tadros

      Kartonnage, 2026

      249 kr

      Lars Kepler - Medusa, Inbunden
      • Nyhet
      Del 11

      Medusa

      Lars Kepler

      Inbunden, 2026

      269 kr

      Peter Englund - Om att misslyckas, Inbunden
      • -17%

      Om att misslyckas

      Peter Englund

      Inbunden, 2026

      3,9 utav 5 stjärnor. Totalt antal röster:(10)

      199 kr239 kr